|
| | FACPreconditioner (std::string object_name, SAMRAI::tbox::Pointer< FACPreconditionerStrategy > fac_strategy, SAMRAI::tbox::Pointer< SAMRAI::tbox::Database > input_db, const std::string &default_options_prefix) |
| |
| | ~FACPreconditioner () |
| |
|
| void | setHomogeneousBc (bool homogeneous_bc) override |
| | Set whether the solver should use homogeneous boundary conditions. More...
|
| |
| void | setSolutionTime (double solution_time) override |
| | Set the time at which the solution is to be evaluated. More...
|
| |
| void | setTimeInterval (double current_time, double new_time) override |
| | Set the current time interval. More...
|
| |
| bool | solveSystem (SAMRAI::solv::SAMRAIVectorReal< NDIM, double > &x, SAMRAI::solv::SAMRAIVectorReal< NDIM, double > &b) override |
| | Solve the linear system of equations \(Ax=b\) for \(x\). More...
|
| |
| void | initializeSolverState (const SAMRAI::solv::SAMRAIVectorReal< NDIM, double > &x, const SAMRAI::solv::SAMRAIVectorReal< NDIM, double > &b) override |
| | Compute hierarchy dependent data required for solving \(Ax=b\). More...
|
| |
| void | deallocateSolverState () override |
| | Remove all hierarchy dependent data allocated by initializeSolverState(). More...
|
| |
|
| virtual void | setNullSpace (bool nullspace_contains_constant_vec, const std::vector< SAMRAI::tbox::Pointer< SAMRAI::solv::SAMRAIVectorReal< NDIM, double >>> &nullspace_basis_vecs=std::vector< SAMRAI::tbox::Pointer< SAMRAI::solv::SAMRAIVectorReal< NDIM, double >>>()) |
| | Set the nullspace of the linear system. More...
|
| |
| virtual bool | getNullSpaceContainsConstantVector () const |
| | Get whether the nullspace of the linear system contains th constant vector. More...
|
| |
| virtual const std::vector< SAMRAI::tbox::Pointer< SAMRAI::solv::SAMRAIVectorReal< NDIM, double > > > & | getNullSpaceBasisVectors () const |
| | Get the basis vectors for the nullspace of the linear system. More...
|
| |
|
| virtual bool | getInitialGuessNonzero () const |
| | Get whether the initial guess is non-zero. More...
|
| |
|
| const std::string & | getName () const |
| | Return the object name. More...
|
| |
| virtual bool | getIsInitialized () const |
| | Return whether the operator is initialized. More...
|
| |
| virtual bool | getHomogeneousBc () const |
| | Return whether the solver is using homogeneous boundary conditions. More...
|
| |
| virtual double | getSolutionTime () const |
| | Get the time at which the solution is being evaluated. More...
|
| |
| virtual std::pair< double, double > | getTimeInterval () const |
| | Get the current time interval. More...
|
| |
| virtual double | getDt () const |
| | Get the current time step size. More...
|
| |
| virtual void | setHierarchyMathOps (SAMRAI::tbox::Pointer< HierarchyMathOps > hier_math_ops) |
| | Set the HierarchyMathOps object used by the solver. More...
|
| |
| virtual SAMRAI::tbox::Pointer< HierarchyMathOps > | getHierarchyMathOps () const |
| | Get the HierarchyMathOps object used by the solver. More...
|
| |
|
| virtual int | getMaxIterations () const |
| | Get the maximum number of nonlinear iterations to use per solve. More...
|
| |
| virtual void | setAbsoluteTolerance (double abs_residual_tol) |
| | Set the absolute residual tolerance for convergence. More...
|
| |
| virtual double | getAbsoluteTolerance () const |
| | Get the absolute residual tolerance for convergence. More...
|
| |
| virtual void | setRelativeTolerance (double rel_residual_tol) |
| | Set the relative residual tolerance for convergence. More...
|
| |
| virtual double | getRelativeTolerance () const |
| | Get the relative residual tolerance for convergence. More...
|
| |
|
| virtual int | getNumIterations () const |
| | Return the iteration count from the most recent solve. More...
|
| |
| virtual double | getResidualNorm () const |
| | Return the residual norm from the most recent iteration. More...
|
| |
|
| SAMRAI::tbox::Pointer< FACPreconditionerStrategy > | d_fac_strategy |
| |
| SAMRAI::tbox::Pointer< SAMRAI::hier::PatchHierarchy< NDIM > > | d_hierarchy |
| |
| int | d_coarsest_ln = 0 |
| |
| int | d_finest_ln = 0 |
| |
| MGCycleType | d_cycle_type = V_CYCLE |
| |
| int | d_num_pre_sweeps = 0 |
| |
| int | d_num_post_sweeps = 2 |
| |
| std::vector< SAMRAI::tbox::Pointer< SAMRAI::solv::SAMRAIVectorReal< NDIM, double > > > | d_residual_vectors |
| |
| std::vector< SAMRAI::tbox::Pointer< SAMRAI::solv::SAMRAIVectorReal< NDIM, double > > > | d_rhs_vectors |
| |
| std::vector< SAMRAI::tbox::Pointer< SAMRAI::solv::SAMRAIVectorReal< NDIM, double > > > | d_correction_vectors |
| |
| void | setInitialGuessNonzero (bool initial_guess_nonzero=true) override |
| | Set whether the initial guess is non-zero. More...
|
| |
| void | setMaxIterations (int max_iterations) override |
| | Set the maximum number of iterations to use per solve. More...
|
| |
| void | setMGCycleType (MGCycleType cycle_type) |
| | Set the multigrid algorithm cycle type. More...
|
| |
| MGCycleType | getMGCycleType () const |
| | Get the multigrid algorithm cycle type. More...
|
| |
| void | setNumPreSmoothingSweeps (int num_pre_sweeps) |
| | Set the number of pre-smoothing sweeps to employ. More...
|
| |
| int | getNumPreSmoothingSweeps () const |
| | Get the number of pre-smoothing sweeps employed by the preconditioner. More...
|
| |
| void | setNumPostSmoothingSweeps (int num_post_sweeps) |
| | Set the number of post-smoothing sweeps to employ. More...
|
| |
| int | getNumPostSmoothingSweeps () const |
| | Get the number of post-smoothing sweeps employed by the preconditioner. More...
|
| |
| SAMRAI::tbox::Pointer< FACPreconditionerStrategy > | getFACPreconditionerStrategy () const |
| | Get the FAC preconditioner strategy objects employed by the preconditioner. More...
|
| |
| | FACPreconditioner ()=delete |
| | Default constructor. More...
|
| |
| | FACPreconditioner (const FACPreconditioner &from)=delete |
| | Copy constructor. More...
|
| |
| FACPreconditioner & | operator= (const FACPreconditioner &that)=delete |
| | Assignment operator. More...
|
| |
| void | zeroStartCycle (SAMRAI::solv::SAMRAIVectorReal< NDIM, double > &u, SAMRAI::solv::SAMRAIVectorReal< NDIM, double > &f, int level_num, MGCycleType cycle_type) |
| | Apply one cycle of type cycle_type to a zero u on the levels from the coarsest level of the solver through level_num: u = B f. More...
|
| |
| void | improveCycle (SAMRAI::solv::SAMRAIVectorReal< NDIM, double > &u, const SAMRAI::solv::SAMRAIVectorReal< NDIM, double > &f, int level_num, MGCycleType cycle_type) |
| | Apply one cycle of type cycle_type to a nonzero u on the levels from the coarsest level of the solver through level_num: u += B (f - A u), where B is zeroStartCycle(). More...
|
| |
| void | allocateCycleScratchData (const SAMRAI::solv::SAMRAIVectorReal< NDIM, double > &solution, const SAMRAI::solv::SAMRAIVectorReal< NDIM, double > &rhs) |
| | Allocate any missing scratch data required by the current cycle options. More...
|
| |
| void | getFromInput (SAMRAI::tbox::Pointer< SAMRAI::tbox::Database > db) |
| |
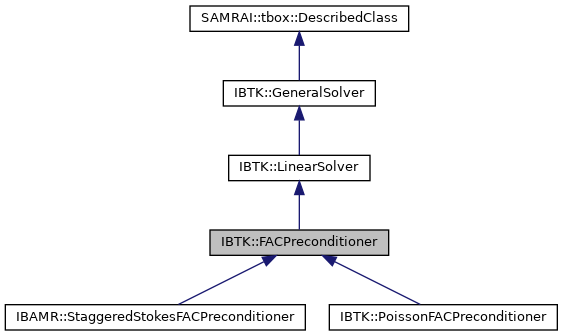
This class is similar to the SAMRAI class SAMRAI::solv::FACPreconditioner, except that this class has been optimized for the case in which the solver is to be used as a single-pass preconditioner, especially for the case in which pre-smoothing sweeps are not needed. This class is not suitable for use as a stand-alone solver; rather, it is intended to be used in conjunction with an iterative Krylov method.
The preconditioner is a fixed linear operator only if every operation of its strategy is linear. A nonlinear preconditioner requires a flexible Krylov method such as FGMRES, or Richardson iteration.
Sample parameters for initialization from database (and their default values):
cycle_type = "V_CYCLE"  // see setMGCycleType()
num_pre_sweeps = 0      // see setNumPreSmoothingSweeps()
num_post_sweeps = 2     // see setNumPostSmoothingSweeps()
enable_logging = FALSE  // see setLoggingEnabled()
Before calling solveSystem(), the form of the solution x and right-hand-side b vectors must be set properly by the user on all patch interiors on the specified range of levels in the patch hierarchy. The user is responsible for all data management for the quantities associated with the solution and right-hand-side vectors. In particular, patch data in these vectors must be allocated prior to calling this method.
Ghost values of x are unspecified on return. Ghost values of b may be overwritten.
- Note
- Without presmoothing, interior values of b on coarse cells covered by finer levels are overwritten.
- Parameters
-
| x | solution vector |
| b | right-hand-side vector |
Conditions on Parameters:
- vectors x and b must have same patch hierarchy
- vectors x and b must have same structure, depth, etc.
- vectors that span more than one level must start at level zero
- vectors x and b must not share component patch-data indices
- Note
- The vector arguments for solveSystem() need not match those for initializeSolverState(). However, there must be a certain degree of similarity, including:
- hierarchy configuration (hierarchy pointer and range of levels)
- number, type and alignment of vector component data
- ghost cell widths of data in the solution x and right-hand-side b vectors
- Note
- The solver need not be initialized prior to calling solveSystem(); however, see initializeSolverState() and deallocateSolverState() for opportunities to save overhead when performing multiple consecutive solves.
- See also
- initializeSolverState
-
deallocateSolverState
- Returns
true if the solver converged to the specified tolerances, false otherwise
Implements IBTK::GeneralSolver.
By default, the solveSystem() method computes some required hierarchy dependent data before solving and removes that data after the solve. For multiple solves that use the same hierarchy configuration, it is more efficient to:
- initialize the hierarchy-dependent data required by the solver via initializeSolverState(),
- solve the system one or more times via solveSystem(), and
- remove the hierarchy-dependent data via deallocateSolverState().
Note that it is generally necessary to reinitialize the solver state when the hierarchy configuration changes.
When linear operator or preconditioner objects have been registered with this class via setOperator() and setPreconditioner(), they are also initialized by this member function.
- Parameters
-
| x | solution vector |
| b | right-hand-side vector |
Conditions on Parameters:
- vectors x and b must have same patch hierarchy
- vectors x and b must have same structure, depth, etc.
- vectors that span more than one level must start at level zero
- Note
- The vector arguments for solveSystem() need not match those for initializeSolverState(). However, there must be a certain degree of similarity, including:
- hierarchy configuration (hierarchy pointer and range of levels)
- number, type and alignment of vector component data
- ghost cell widths of data in the solution x and right-hand-side b vectors
- Note
- It is safe to call initializeSolverState() when the state is already initialized. In this case, the solver state is first deallocated and then reinitialized.
- See also
- deallocateSolverState
Reimplemented from IBTK::GeneralSolver.